


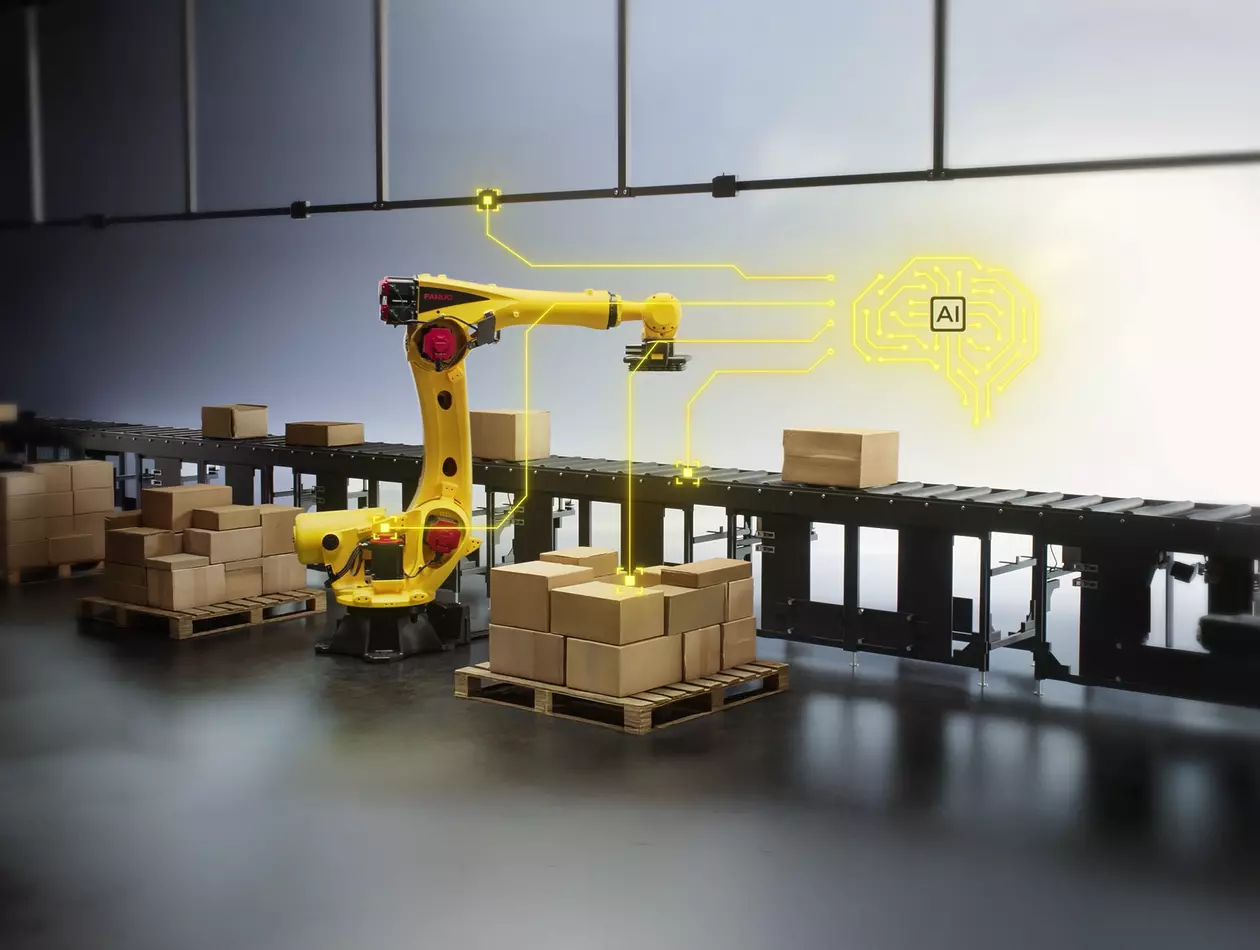
FANUC ROS 2 Driver for Industrial Robot Integration
Integrate FANUC Robots with ROS 2 Driver
FANUC has released its ROS 2 driver for the CRX collaborative robot series, enabling seamless integration with the Robot Operating System 2 (ROS 2). This gives developers, researchers, and manufacturers greater flexibility to create intelligent robotic applications using a modern, scalable framework designed for real-time robot control and advanced automation.
What is the FANUC ROS 2 Driver?
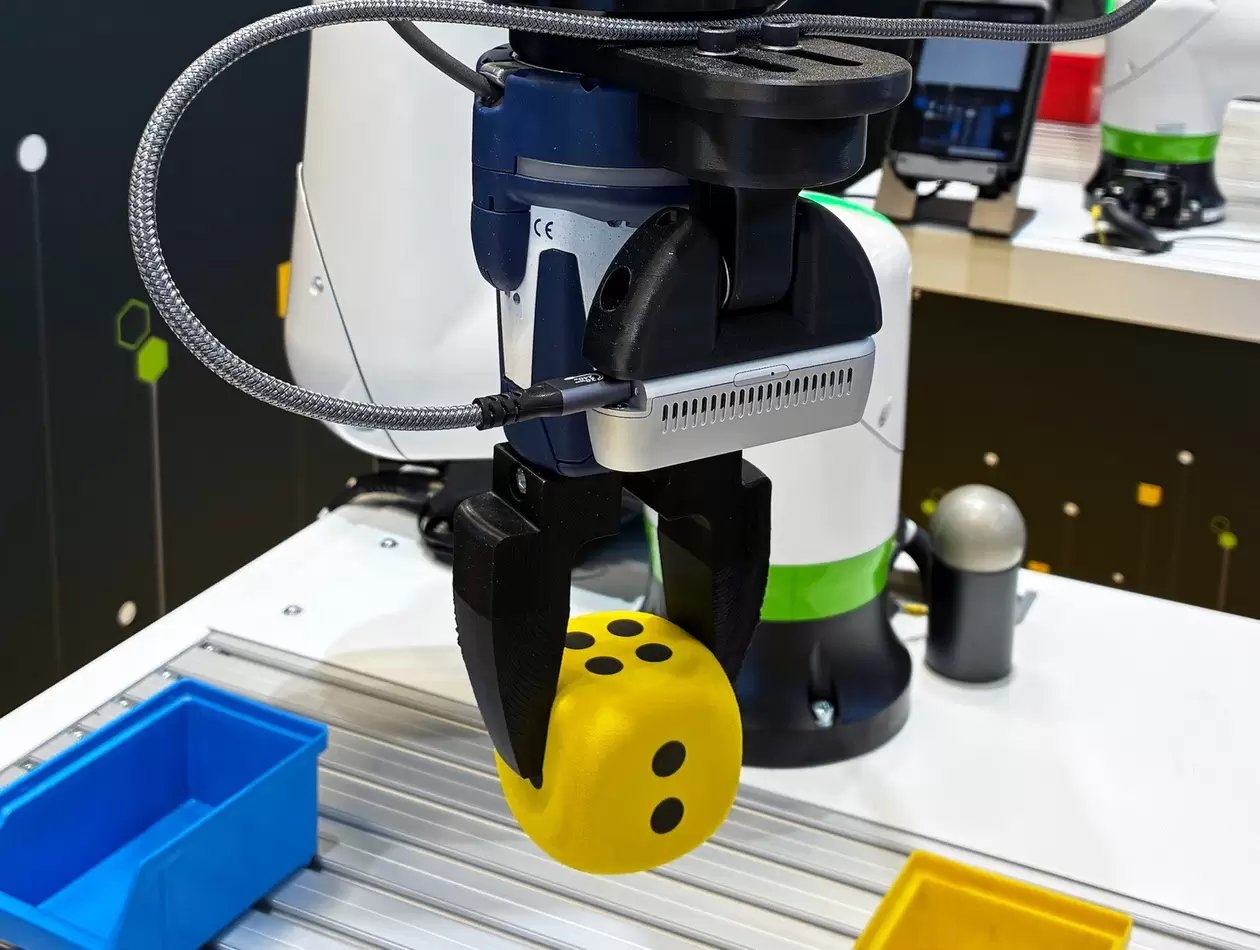
The FANUC ROS 2 driver is a software interface that connects FANUC CRX Collaborative Robots to the ROS 2 ecosystem. It empowers users to leverage open-source tools for advanced automation, research, and industrial deployment. The driver supports high-frequency control, MoveIt integration, and simulation capabilities, enabling flexible deployment across research and production environments.
Get Started with the FANUC ROS 2 Driver
The FANUC ROS 2 driver is available now for the CRX Collaborative Robot Series and several other models. Developers can access documentation, installation guides, and support via FANUC CORPORATION’s official GitHub repositories.
Physical AI Applications - Enabling Physical AI Through Open ROS Integration
Real-Time, High-Frequency Motion Control
Advanced Motion Planning & Collision Avoidance
Simulation & Virtual Prototyping
Flexible Integration
Broad Model Support
Industrial-Grade Reliability
*ROS is a trademark of the Open Source Robotics Foundation.
**Python is a registered trademark of the Python Software Foundation.
***GitHub is a registered trademark of GitHub, Inc.